
Experimental Study on Practicing Strategy of Visual Interfaces for Remote Handling Tasks
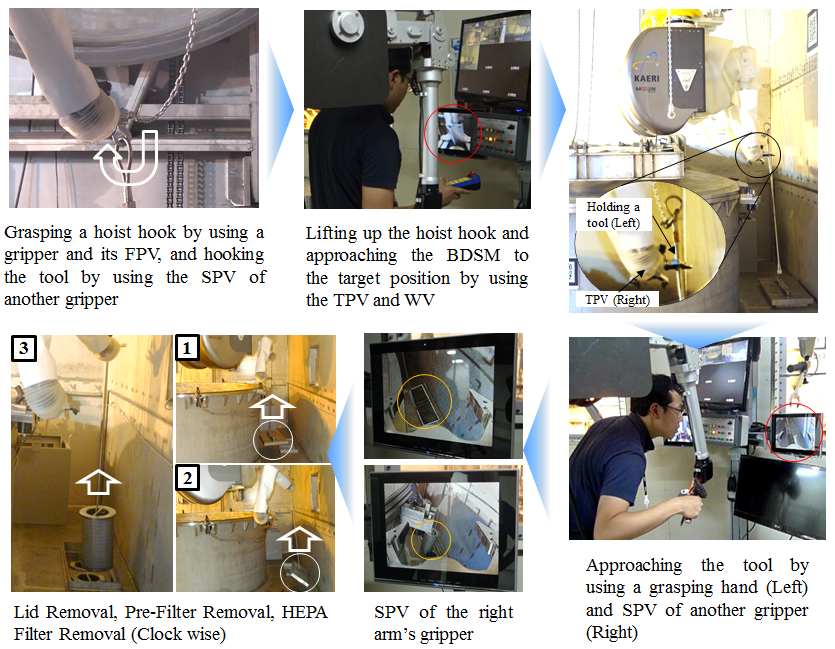
A remote handling strategy for the developed teleoperation system is proposed based on the ecological analysis of the system, and the performance for the practical facility is evaluated using the proposed knowledge.
The teleoperation manipulators presented in this study are applied for the remote handling and management of pyroprocessing related facilities of an argon cell located in KAERI. BDSM (Bridge Transported Servo Manipulator) is based on servo-driven actuators and travels the entire cell area using a bridge transport system.
Despite the dexterous dual-arm manipulators and redundant monitoring systems, many professional operators have trouble operating these remote handling systems because of the lack of a utilization strategy for the installed camera systems, and the burden of recognizing the gripper pose which may fall outside the field of vision.