
Utilizing Catmull-rom Splines, Hand Tracking Technology, and Eye Tracking Technology
This research focuses on enhancing the user experience and control efficiency in remote robotic systems using virtual reality technology. We leverage advanced hand-tracking and eye-tracking methods to create an intuitive teleoperation framework, aimed at improving task accuracy and reducing operational complexity.
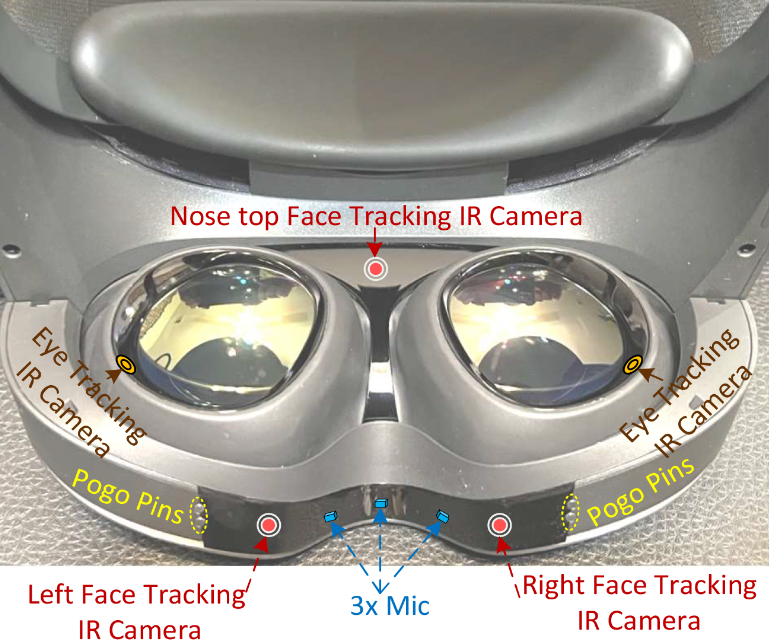
The system employs a “virtual hand” approach where the user’s hand movements, detected through a Meta Quest Pro, are directly translated into robot actions. To address mode-switching within a fully immersive environment, eye-tracking enables users to switch modes without disengaging their hands from control tasks.
A notable aspect is the integration of Catmull-Rom splines for smooth trajectory planning, allowing the robot to follow curved paths based on predefined control points. This improves path-following performance in confined or hazardous environments.
Validation experiments demonstrate that the system significantly reduces task execution time compared to traditional control methods, allowing a single operator to handle tasks that typically require multiple personnel.